Hardware
← homeThings I build when software isn't enough.
Self-directed prototypes across flight, high-voltage experiments, and field sensing. Real hardware, measured outcomes, and the failures left intact.
SCAR — AirBike
A self-funded, single-rider eVTOL experiment built on an eight-rotor ducted-fan platform. The airframe combined welded aluminium, carbon-fiber booms, custom motor mounts, and large protective ducts.
The prototype never reached a safe or practical flight margin. Development stopped, but the build and its outcome remain worth documenting.
Read the full retrospectiveSCQ — Experimental propulsion
Ten physical prototype generations spanning waterjet-cut electrode stacks, PTFE and Kartit dielectrics, high-voltage lab campaigns, magnetic shielding, and a vacuum chamber.
Measured outcome: no verified thrust. The largest apparent effects were traced to the dynamometer responding to the electric field—an instrumentation artifact, not propulsion.
Open the prototype archive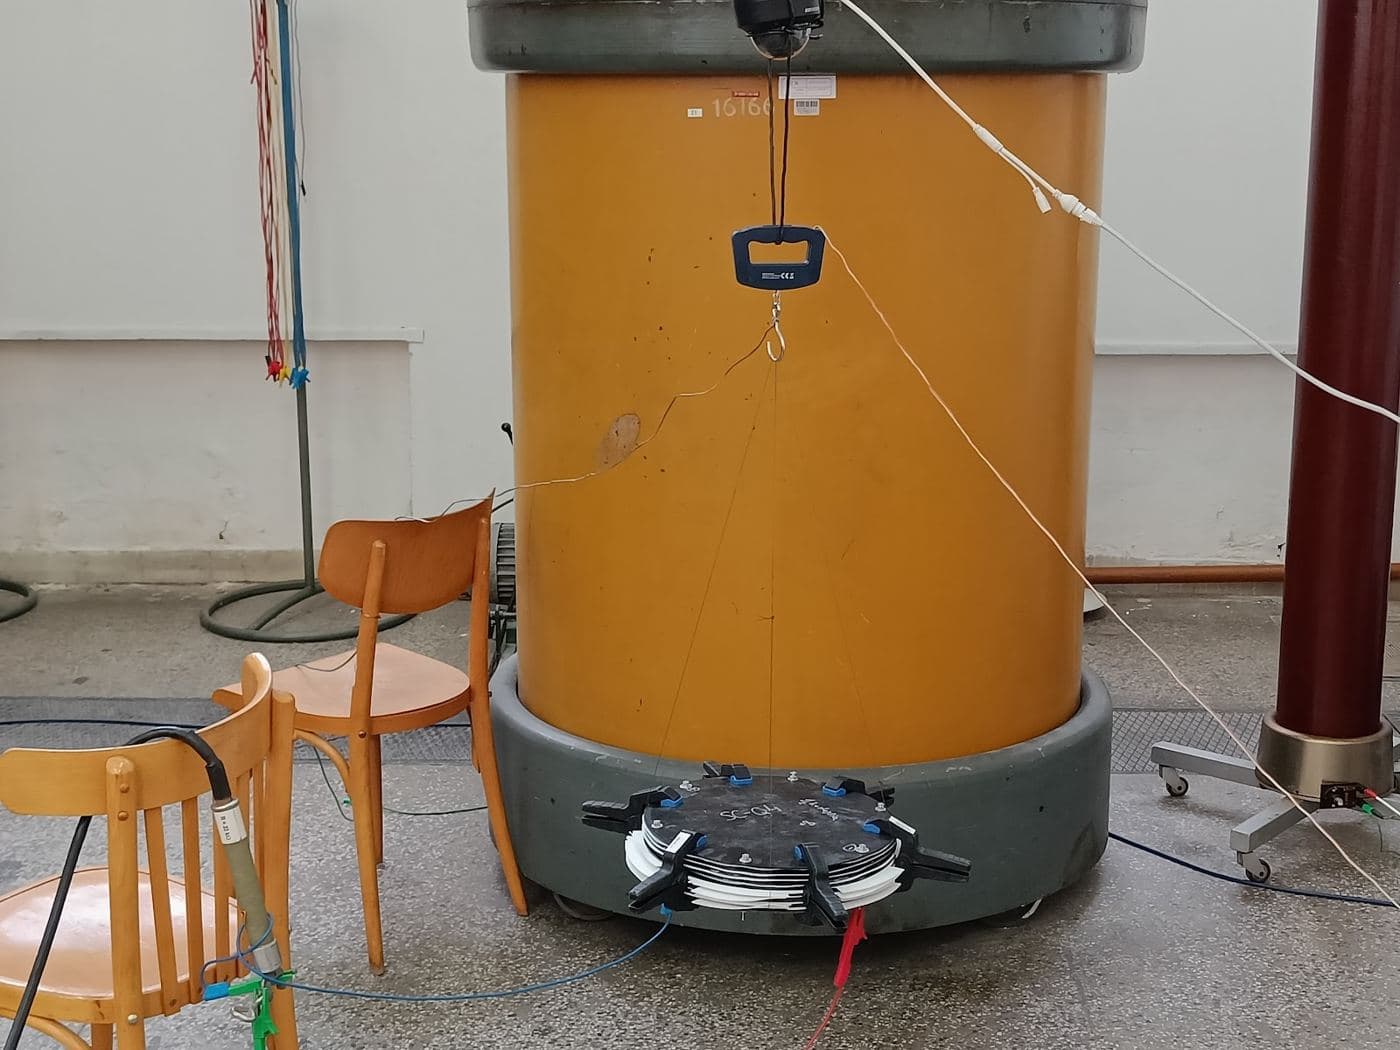
Payload architecture
Sensing
2× HMC5883L-compatible magnetometers
Compute
Raspberry Pi 3 + PCA9548A I²C multiplexer
Position
u-blox 7 GPS + CSV logging
Feedback
Differential threshold + audio and RGB alerts
field difference → threshold → GPS-tagged detection
Drone-mounted iron detector
A Raspberry Pi payload that compares two magnetometers to detect buried ferromagnetic objects, attaches GPS coordinates to each reading, and produces immediate local alerts.
The Python implementation includes sensor and GPS readers, calibration, CSV data logging, status LEDs, audio alerts, and hardware self-tests.
Explore the build and gallery