Hardware · field sensing
← hardwareDrone-mounted iron detector
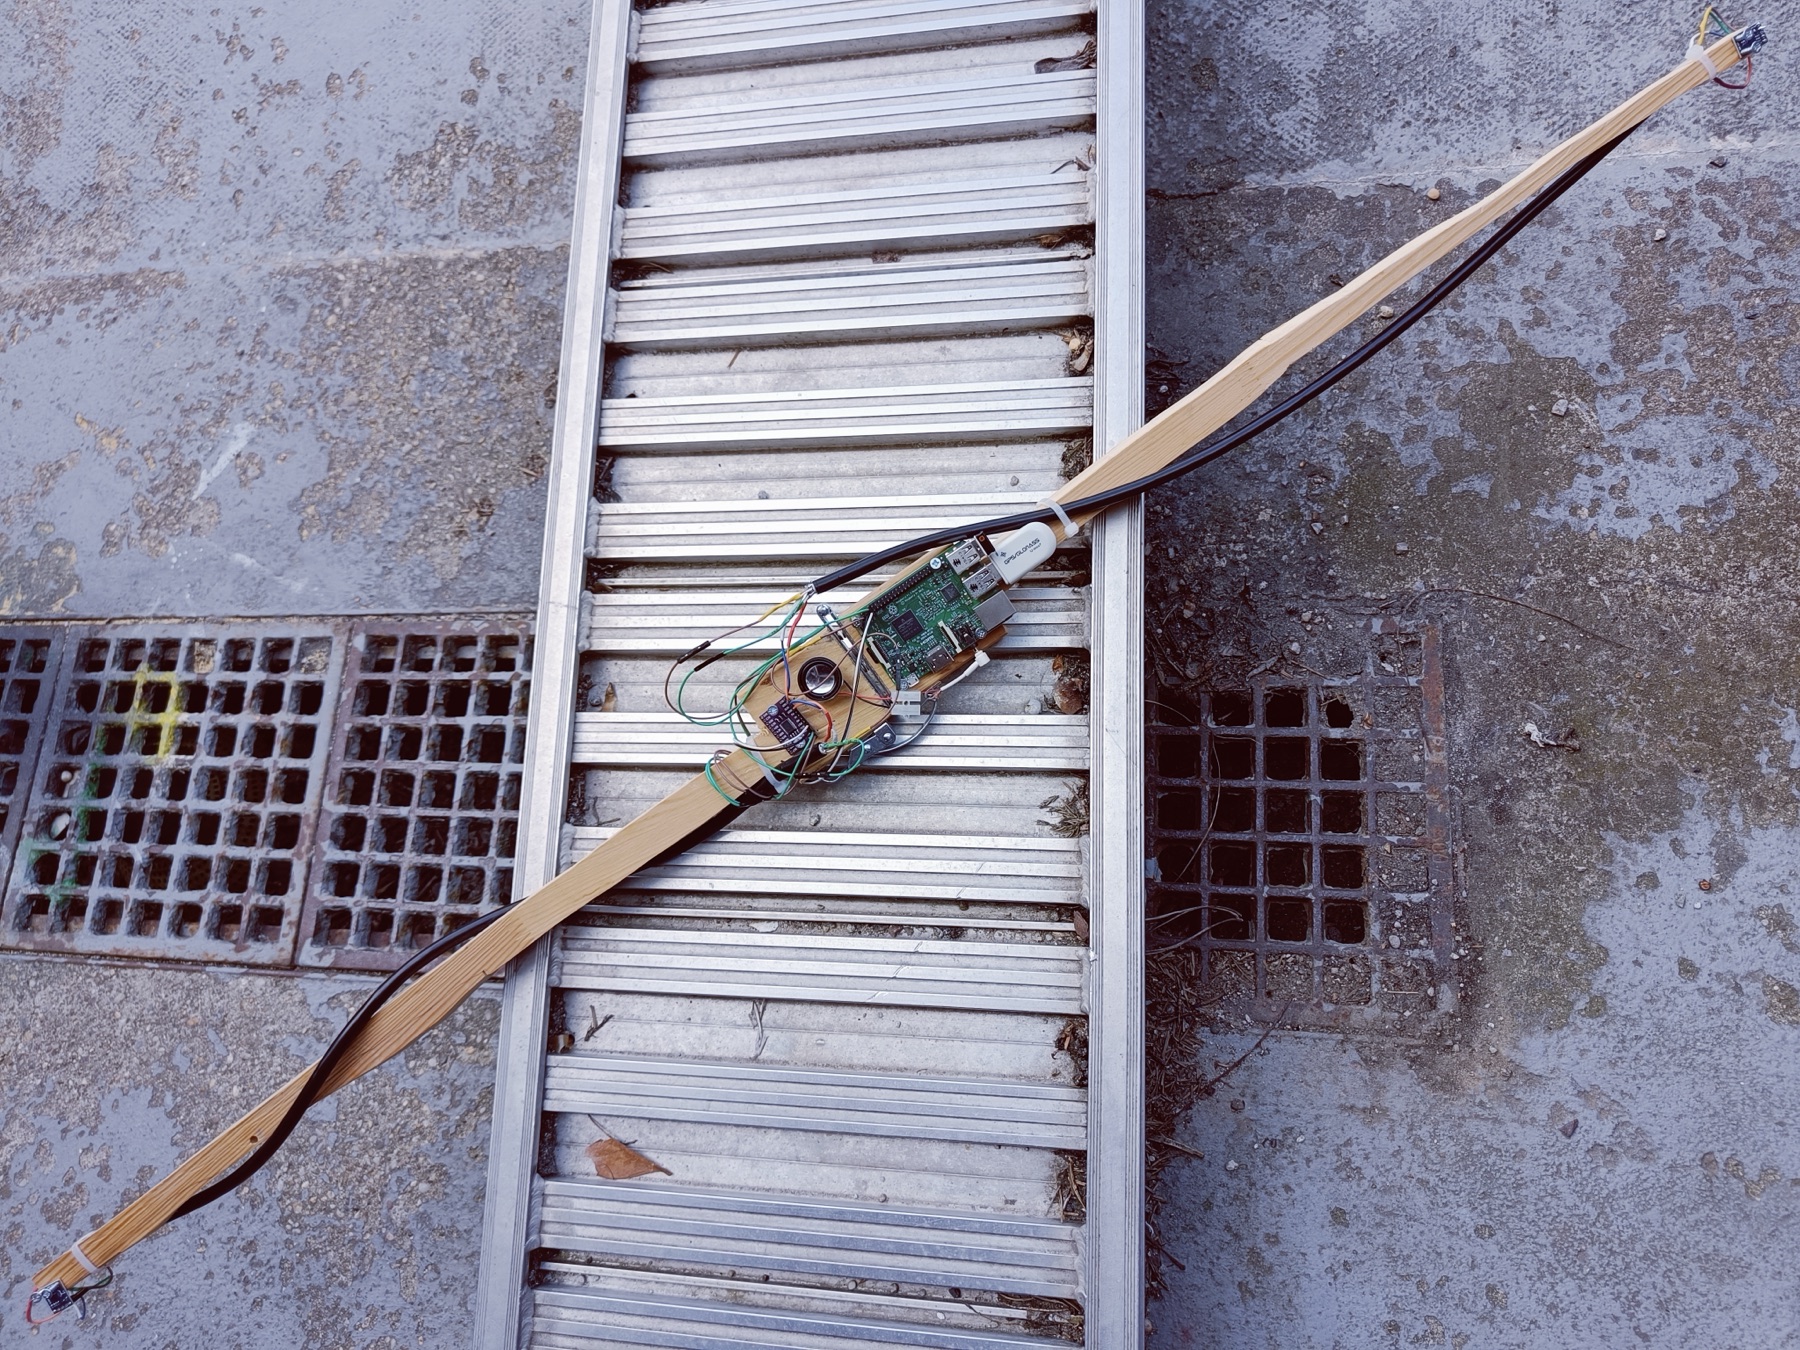
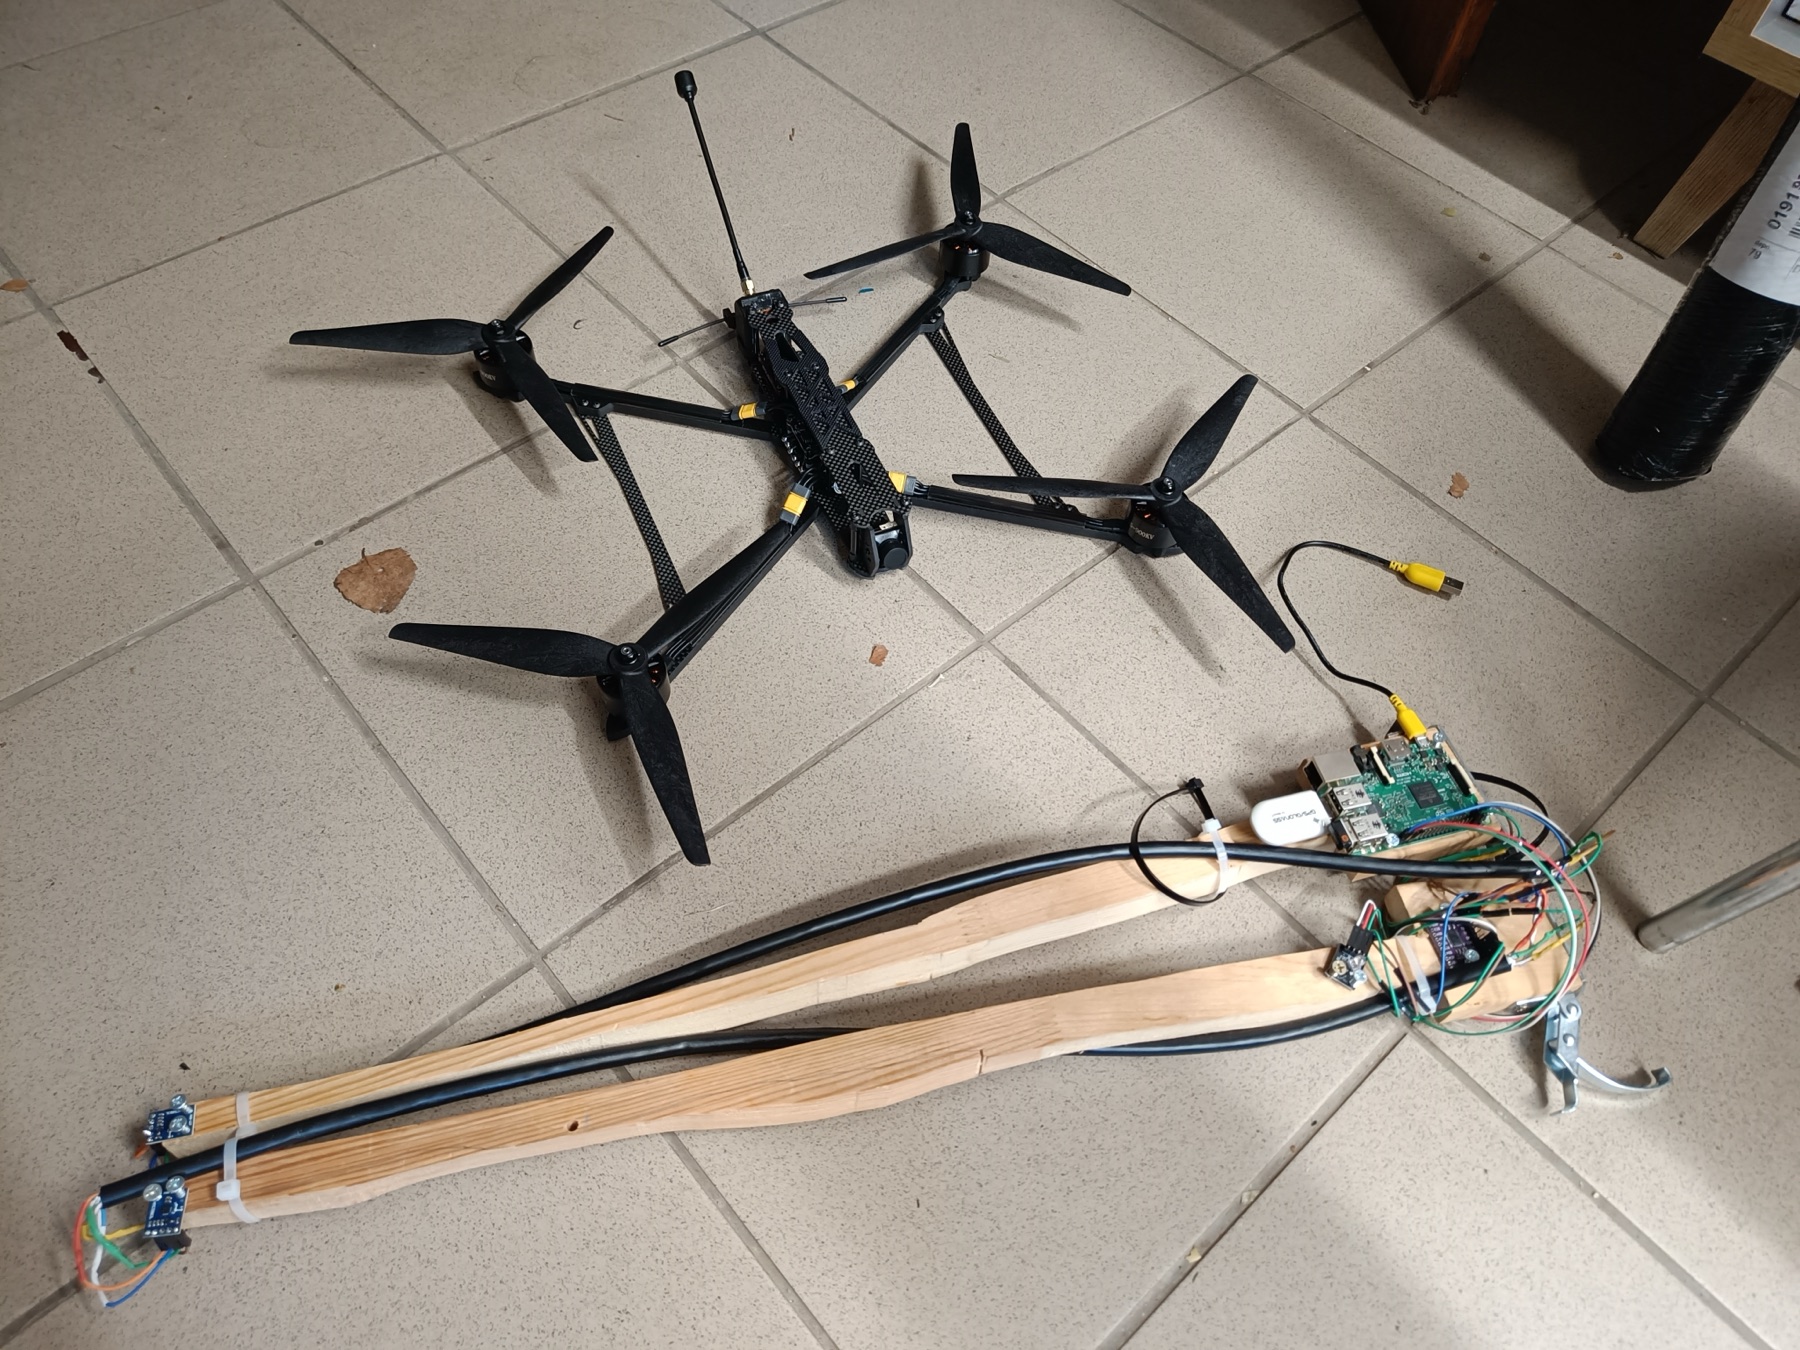
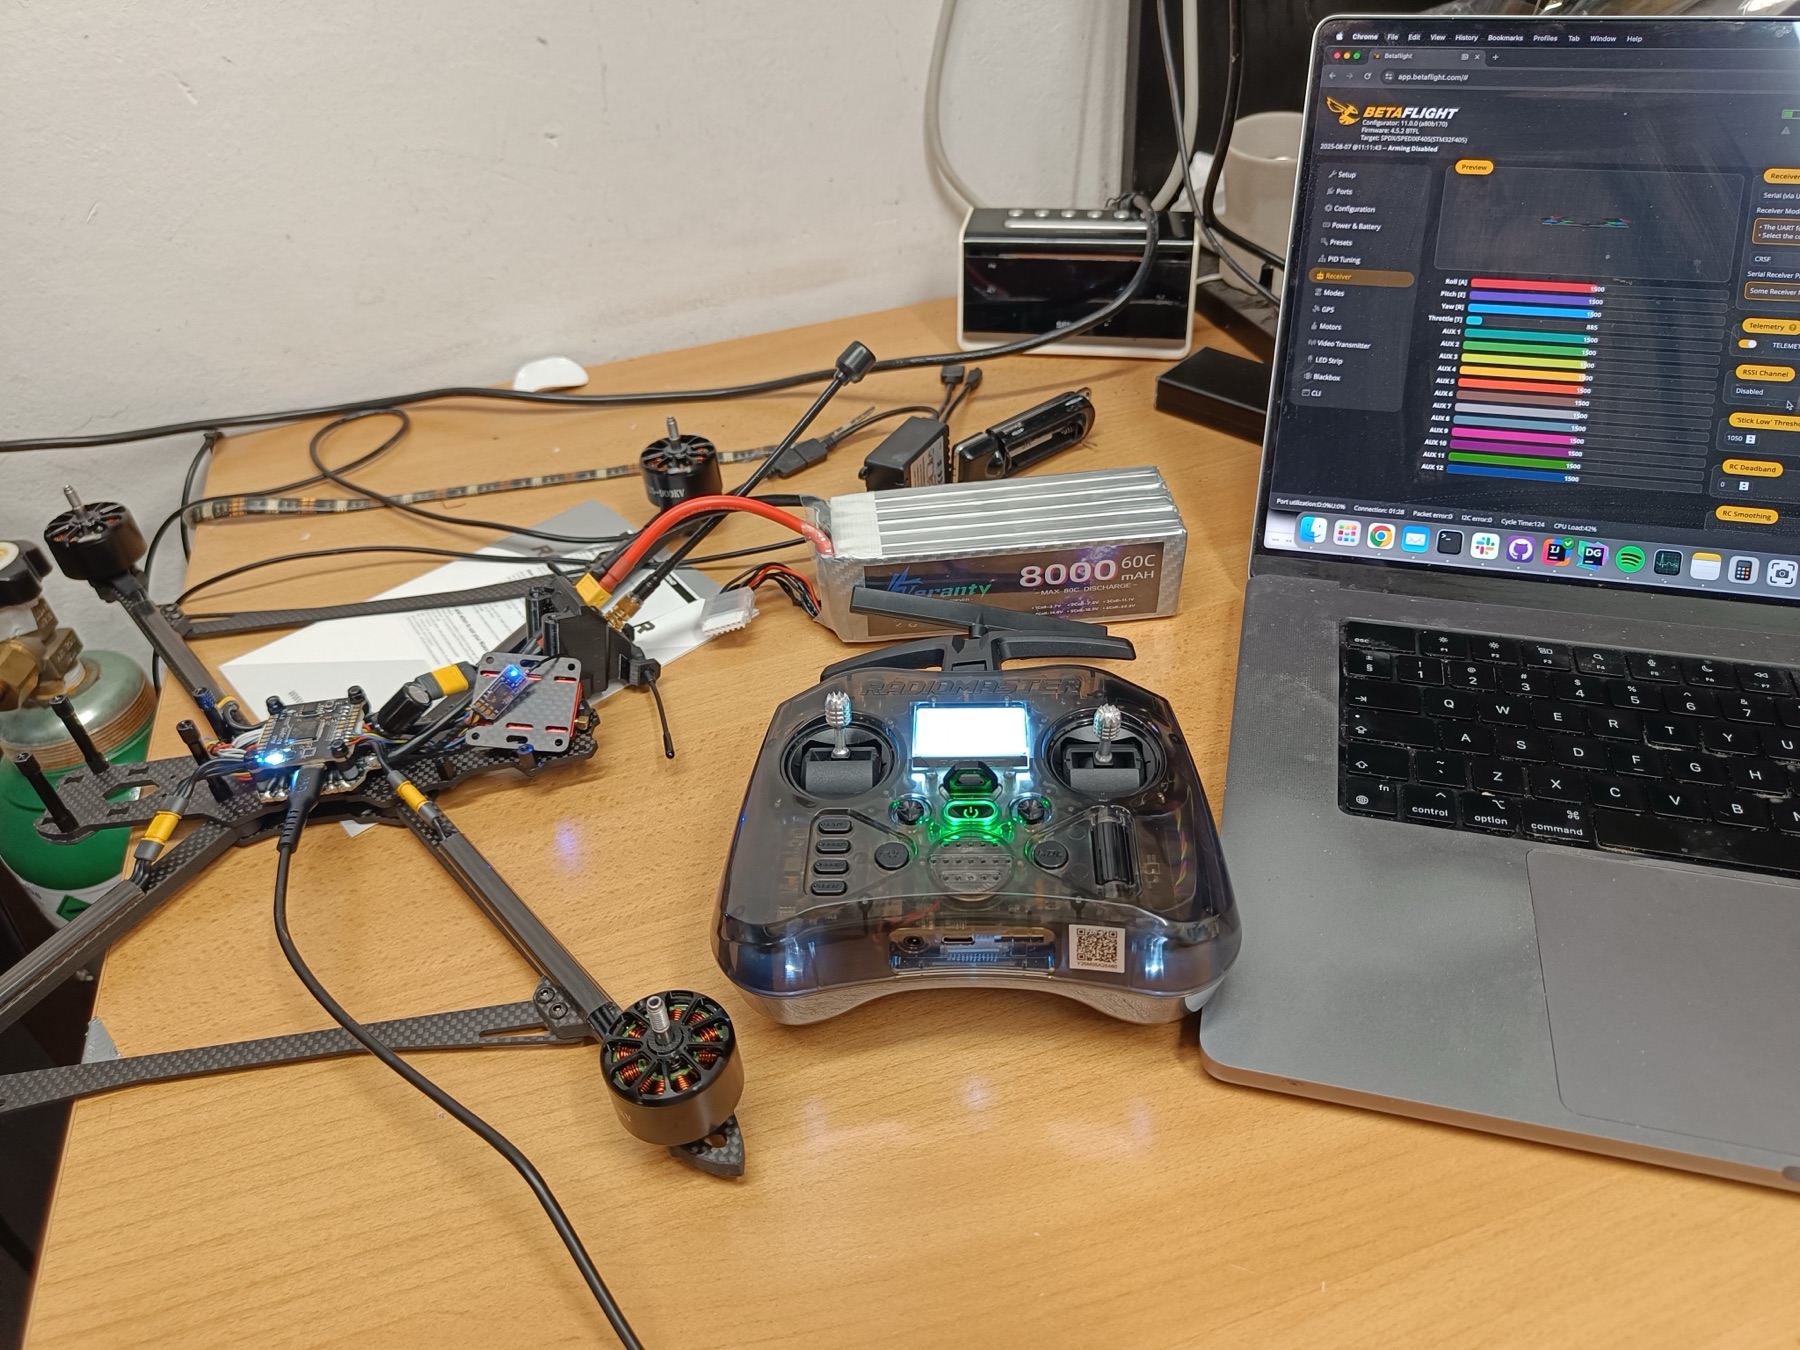
A differential magnetic-sensing payload built to find buried ferromagnetic objects from the air. Two separated magnetometers feed a Raspberry Pi, which compares their readings, attaches GPS coordinates, logs the result, and alerts when the field difference crosses a threshold.
Build gallery
How it works
- 01The two magnetometers sample the field at opposite ends of a long baseline.
- 02Calibration removes the static offset, then the software tracks the difference between the sensors rather than absolute heading.
- 03Threshold crossings trigger audio and LED feedback while the GPS position and raw values are written to CSV.
This is specifically an iron and ferromagnetic-object detector, not a general detector for non-ferrous metals.
Payload
- Compute
- Raspberry Pi 3
- Sensors
- 2× HMC5883L-compatible magnetometers
- Sensor bus
- PCA9548A I²C multiplexer
- Position
- u-blox 7 GPS receiver
- Feedback
- RGB status LED and audio alert
- Output
- GPS-tagged CSV measurements
Python source
Sensor and GPS readers, calibration, logging, status output, alerts, and hardware self-tests are published in the repository.